Papers
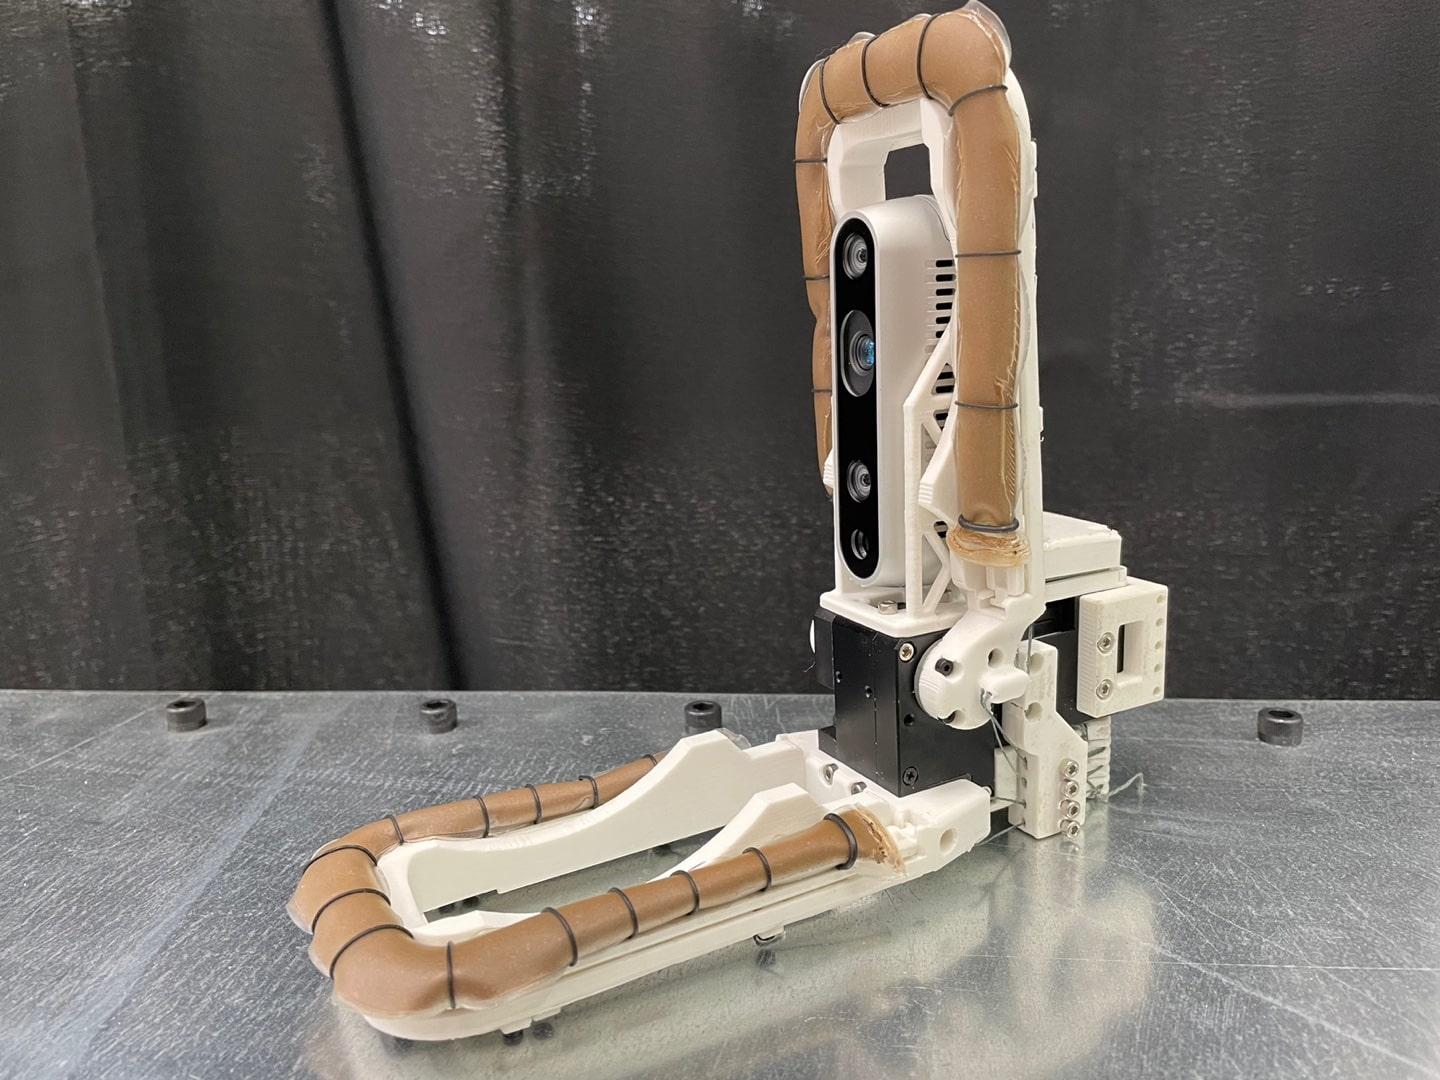
These publications document the research progression from local contact adaptation to geometric retention and global self-alignment.
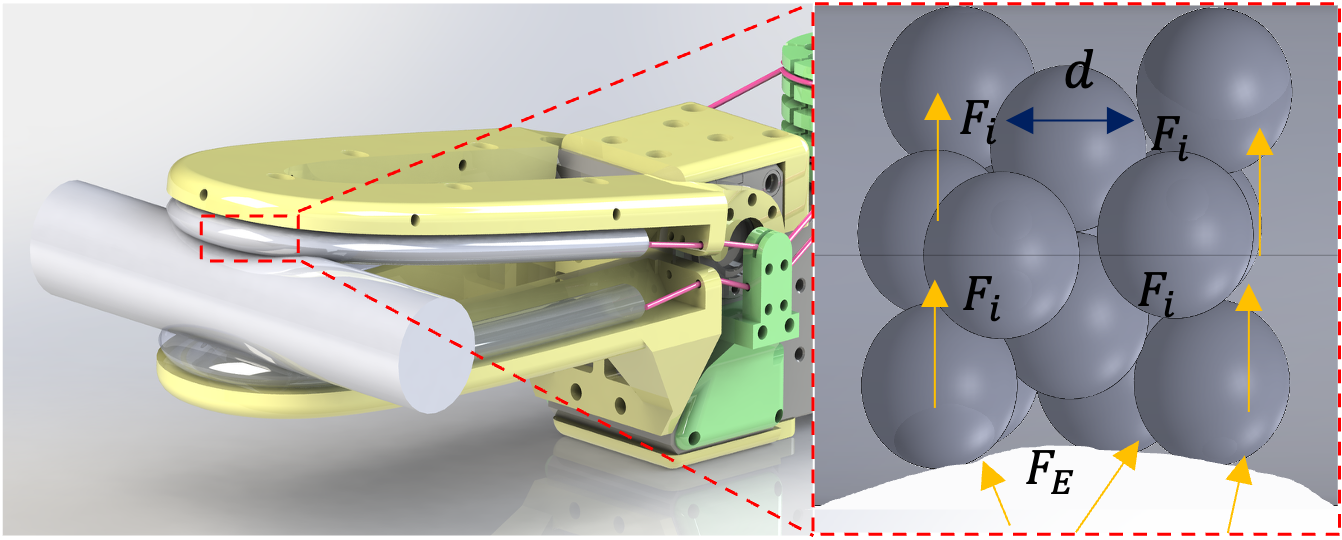
1. Lip-Inspired Passive Jamming Gripper
@INPROCEEDINGS{hong2022lip,
  author={Hong, Jooyoung and Mathur, Dhruv C and Kim, Joohyung},
  booktitle={2022 IEEE 5th International Conference on Soft Robotics (RoboSoft)},
  title={Lip-Inspired Passive Jamming Gripper},
  year={2022},
  pages={306-311},
  doi={10.1109/RoboSoft54090.2022.9762187}}
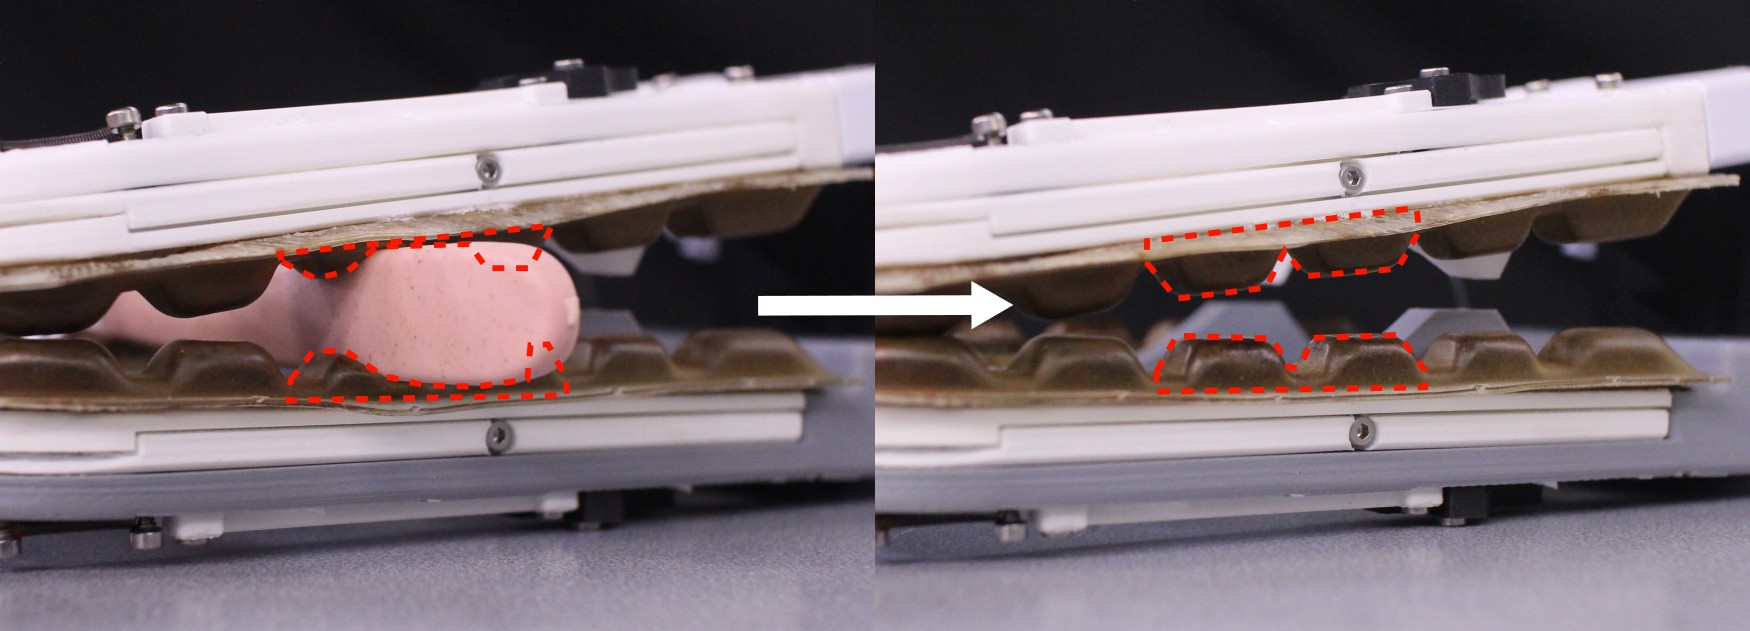
2. Lip-Inspired Passive Jamming Gripper with Teeth Structure
@INPROCEEDINGS{hong2023lip,
  author={Hong, Jooyoung and Shin, Kazuki and Mathur, Dhruv C and Yamsani, Sankalp and Yim, Joohee and Kim, Joohyung},
  booktitle={2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  title={Lip-Inspired Passive Jamming Gripper with Teeth Structure},
  year={2023},
  pages={4518-4524},
  doi={10.1109/IROS55552.2023.10342175}}
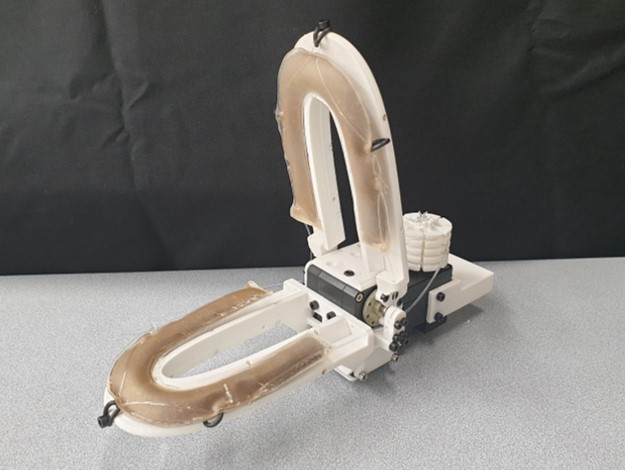
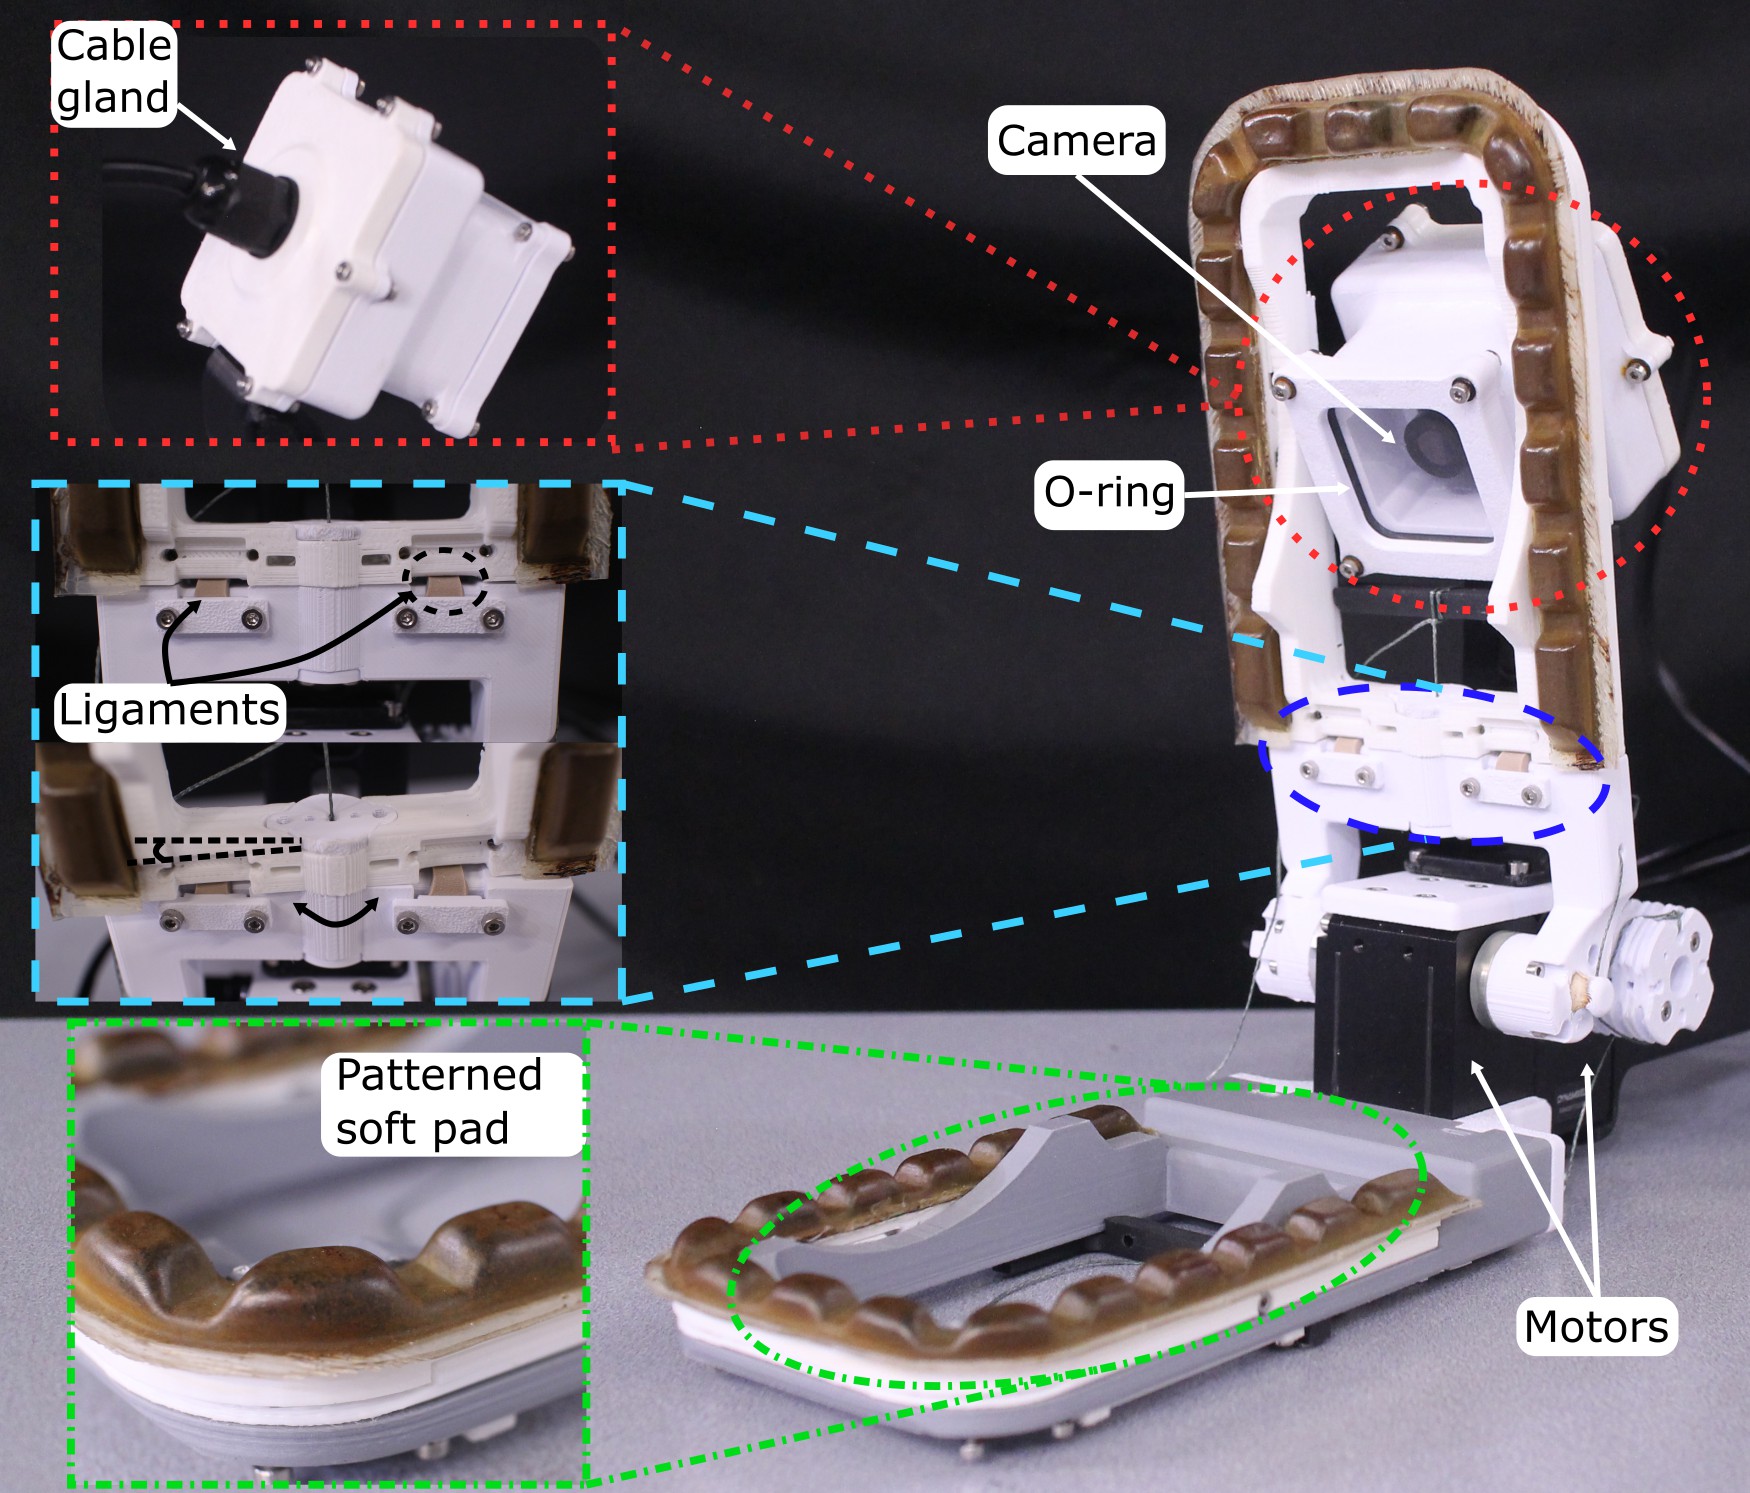
3. Robust Underwater Grasping of Sloped Objects with a Waterproof Passive Adaptive Gripper
@inproceedings{hong2026,
  author    = {Hong, Jooyoung and Hong, Daewon and Kim, Joohyung},
  title     = {Robust Underwater Grasping of Sloped Objects with a Waterproof Passive Adaptive Gripper},
  booktitle = {2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year      = {2026},
}